Robotics Researcher
Haoran (Cris) Wang
Hi, I am Haoran, an M.S. student in Mechanical Engineering at Johns Hopkins University. I received my B.Eng. in Robotics Engineering from the Southern University of Science and Technology.
My research focuses on robot manipulation, robot learning, dexterous manipulation, and embodied AI. I am interested in building robots that can perceive, learn, and interact reliably in the physical world.
Selected work
Research
3D Perception
Persistent Object-Centric 3D Memory
An RGB-D perception pipeline that combines plane removal, point-cloud clustering, SAM2 mask refinement, and world-frame 3D centroids to maintain an object-centric scene representation.
Robot Learning
Humanoid Teleoperation and Motion Retargeting
A modular system that unifies PICO, Xsens, and camera-based human motion for humanoid retargeting, replay, and robot deployment.
Embodied Perception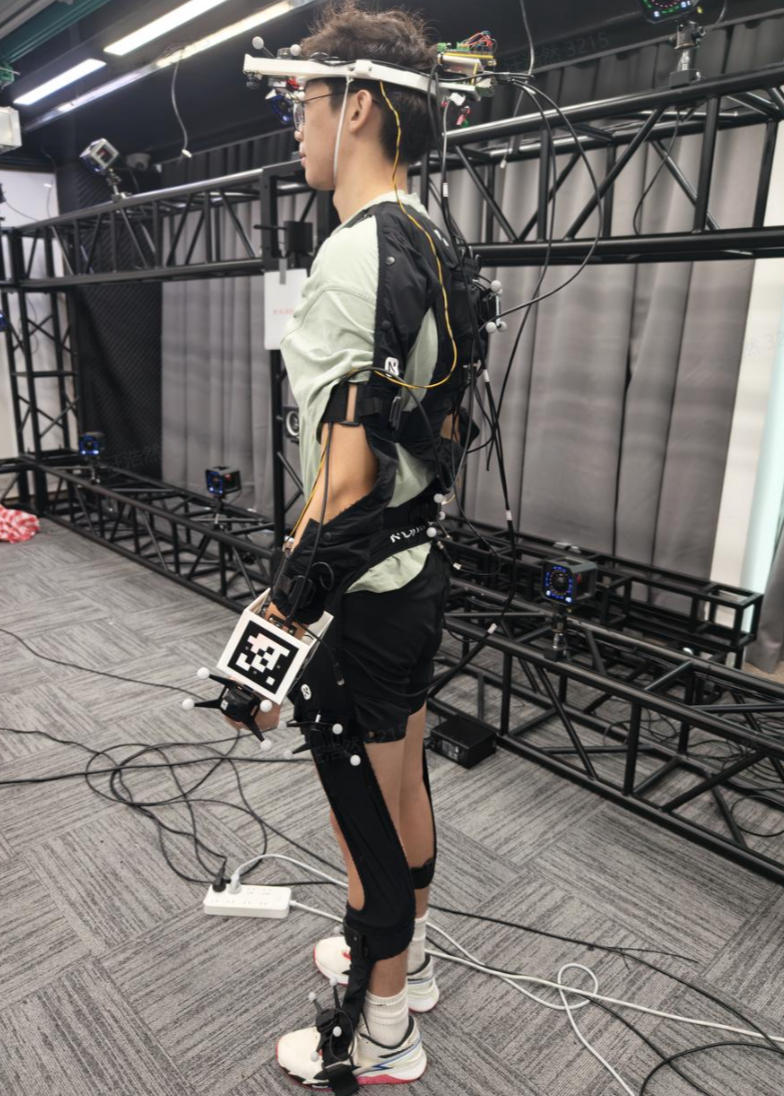
Egocentric Full-Body Pose Recovery
A synchronized wearable capture and multi-view reconstruction platform for learning full-body pose from head- and wrist-mounted fisheye cameras.
Projects
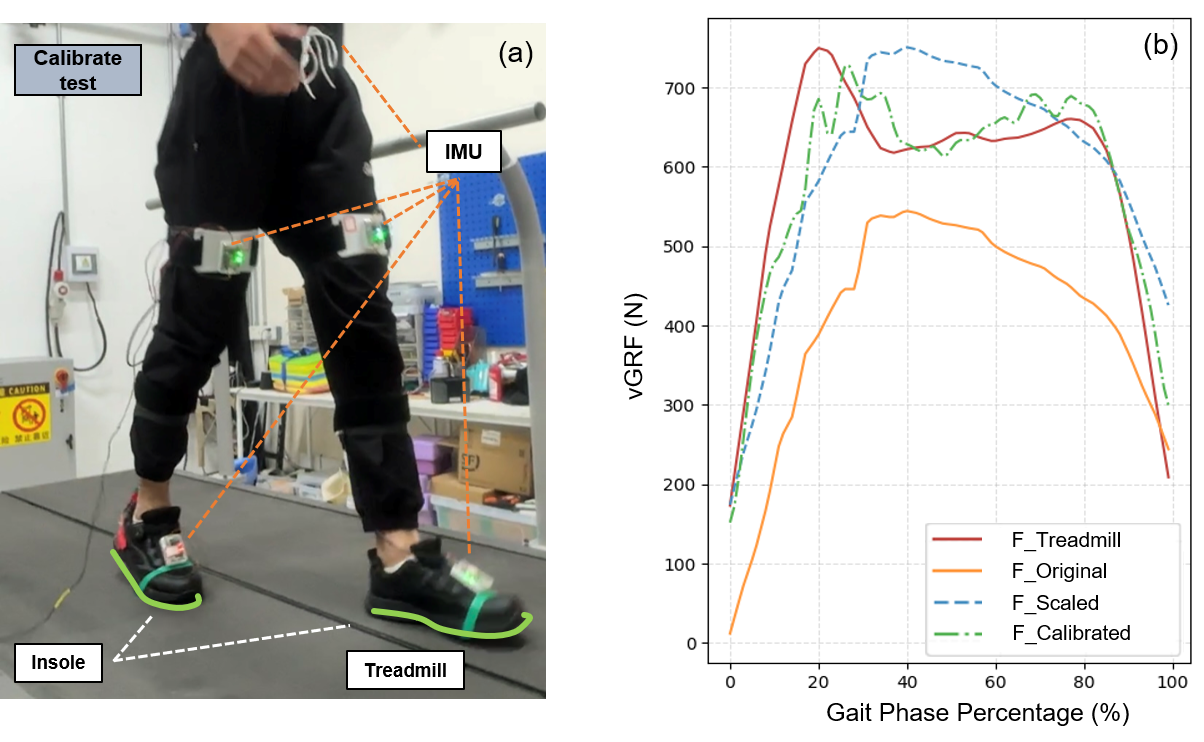
Self-Calibration for Resistive Insole Pressure Sensors
An optimization-based calibration method for wearable pressure sensing that reduces vertical ground-reaction-force error.

SWhegPro3 Wheel-Leg Transformable Robot
A four-module mobile robot with transformable three-impeller wheels for robust stair climbing across varied dimensions.

Drawing Robot Based on the Gen3-lite Robot Arm
A vision-guided drawing system that turns input graphics into end-effector trajectories on tilted work surfaces.